RF Remote Control Wireless 4-Wheel Robotic Car Using Arduino
A complete, step-by-step guide to building a wireless RF-controlled robotic car using Arduino Uno, L298 motor driver, 18650 batteries, and the NIC2262/2272 RF module — perfect for FYPs, school science projects, and DIY robotics enthusiasts in Lahore and beyond.
Introduction
Robotics is one of the most exciting fields in engineering today, blending mechanical, electrical, and computer engineering into hands-on, practical projects. Building a wireless 4-wheel robotic car is a fantastic way to apply core concepts of automation, embedded systems, and wireless communication — all in a single build.
This project is ideal for students and engineers in Lahore, Pakistan — whether you’re working on a final year project (FYP), a university lab assignment, or a personal DIY build. You’ll learn how to wire up the components, write functional Arduino code, and understand the role each part plays in making the car move wirelessly via RF remote control.
Components Required
Here is everything you need before getting started:
| No. | Component | What It Does | Price at QKZEE |
|---|---|---|---|
| 01 | Arduino UNO R3 DIP | The main microcontroller — handles all logic, pin control, and RF signal reading. | Rs 1,200 |
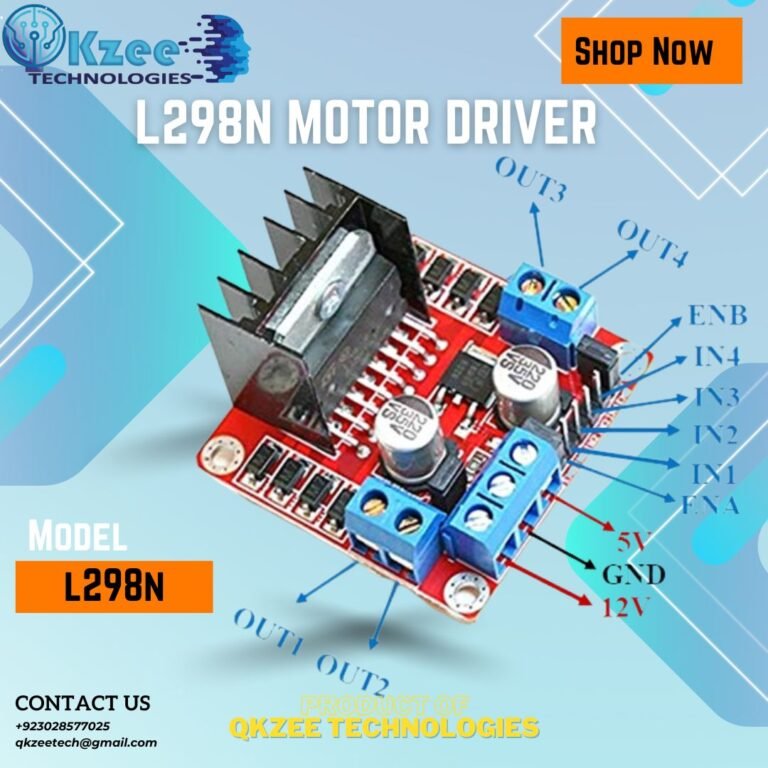
| 02 | L298N Motor Driver | Dual H-Bridge driver that lets Arduino control high-current DC motors. | Rs 375 |
| 03 | DC Gear Motors ×4 | Provide rotational motion for all four wheels of the robotic car. | Rs 165 each |
| 04 | NIC2262 / NIC2272 RF module | RF transmitter (2262) and receiver (2272) for wireless remote control. | Available on order — message us on WhatsApp |
| 05 | 18650 Li-ion Batteries ×2 | Rechargeable cells providing power to both motors and the Arduino board. | Rs 200 (Lot) / Rs 250 (New) each |
| 06 | Single Cell 18650 Battery Holder | Holds 18650 cells securely and provides clean power connections. | Rs 45 |
| 07 | 4WD Robot Car Chassis Kit | 4 wheels + base frame for mounting all components and motors (includes 4 DC gear motors). | Rs 1,925 |
| 08 | ON/OFF Rocker Switch + Jumper Wires | For connections between components. Switch to power the robot on/off. | Rs 30 + Rs 180 |
If you buy the 4WD chassis kit, the four DC gear motors come with it — you don’t need to buy them separately.
Circuit Diagram
The circuit connects the Arduino Uno to the L298 motor driver, which in turn drives the four DC motors. The NIC2272 RF receiver is wired to a digital pin on the Arduino and listens for signals from the handheld NIC2262 RF transmitter. Power comes from the 18650 battery pack, connected via the battery holder to both the motor driver’s VCC and the Arduino’s VIN pin.
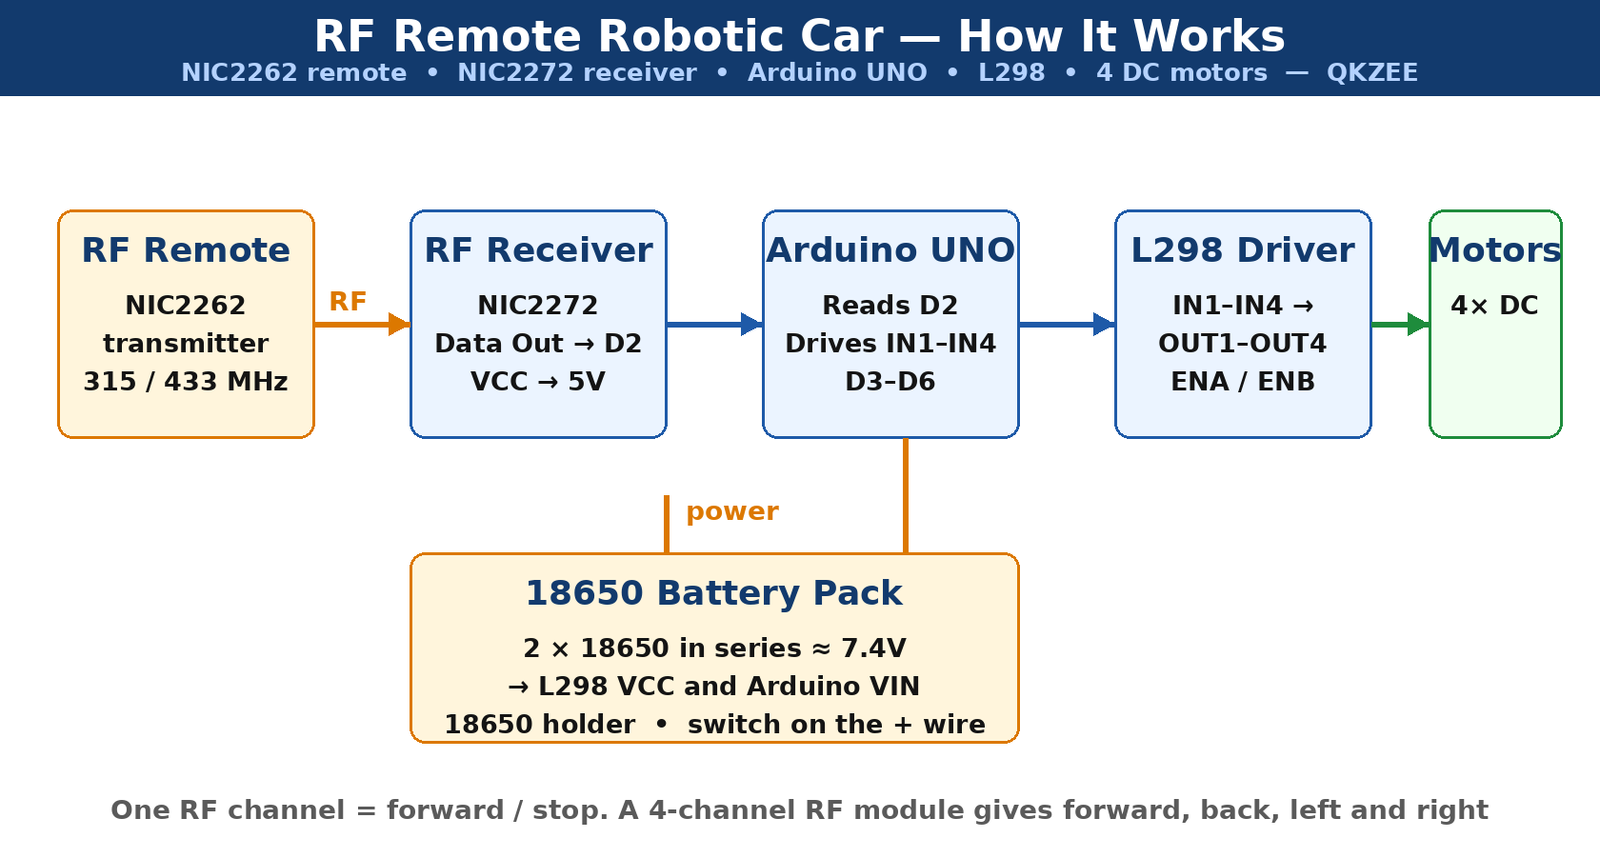
Figure 1 — Block diagram: RF Remote → Receiver → Arduino UNO → L298 → DC Motors
Pin Configuration & Connections
Arduino Uno
| Arduino Pin | Connected To | Function |
|---|---|---|
| D2 | RF Receiver Data Pin | Reads RF HIGH/LOW signal |
| D3 | L298 IN1 | Left motor direction 1 |
| D4 | L298 IN2 | Left motor direction 2 |
| D5 | L298 IN3 | Right motor direction 1 |
| D6 | L298 IN4 | Right motor direction 2 |
| 5V | RF Module VCC | Power for RF receiver |
| GND | Common Ground | Shared ground for all modules |
L298 Motor Driver
| L298 Pin | Connected To | Function |
|---|---|---|
| IN1, IN2 | Arduino D3, D4 | Controls left motor direction |
| IN3, IN4 | Arduino D5, D6 | Controls right motor direction |
| OUT1, OUT2 | Left DC Motors | Motor A output |
| OUT3, OUT4 | Right DC Motors | Motor B output |
| VCC | 18650 Battery + | Motor power supply |
| GND | Common Ground | Shared ground |
| 5V | — | Regulated 5V OUT when the jumper is fitted — it can power the Arduino. Above 12V motor supply, remove the jumper and feed 5V in separately. |
| ENA, ENB | Jumpers fitted | Full speed. Remove the jumpers and feed PWM for speed control — see “Adding Speed Control” below. |
NIC2272 RF Receiver
| RF Module Pin | Connected To |
|---|---|
| VCC | Arduino 5V |
| GND | Common Ground |
| Data Out | Arduino D2 |
Common ground is essential: the Arduino GND, the L298N GND and the battery negative must all be connected together, or the motors will not respond to the Arduino.
A note on speed: the L298N drops about 2V inside the chip, so 7.4V from two 18650 cells gives roughly 5.4V at the motors. That is normal for this driver — if the car feels slower than expected, that is why. For the full explanation, see our L298N motor driver guide.
Arduino Code
The code below reads the RF signal on pin D2 and drives the motors accordingly. When the receiver detects a HIGH signal from the remote, the car moves forward. When the signal goes LOW, the car stops. You can expand this logic to handle multiple RF channels for turning left, right, and reversing.
// ── RF Remote Control Robotic Car ──
// Arduino Uno + L298 Motor Driver + NIC2262/2272 RF Module
// Motor pin definitions
int motor1Pin1 = 3;   // Left motor
int motor1Pin2 = 4;
int motor2Pin1 = 5;   // Right motor
int motor2Pin2 = 6;
int rfPin      = 2;   // RF receiver data pin

void setup() {
  pinMode(motor1Pin1, OUTPUT);
  pinMode(motor1Pin2, OUTPUT);
  pinMode(motor2Pin1, OUTPUT);
  pinMode(motor2Pin2, OUTPUT);
  pinMode(rfPin, INPUT);
}

void loop() {
  int signal = digitalRead(rfPin);

  if (signal == HIGH) {
    // Move Forward
    digitalWrite(motor1Pin1, HIGH);
    digitalWrite(motor1Pin2, LOW);
    digitalWrite(motor2Pin1, HIGH);
    digitalWrite(motor2Pin2, LOW);
  } else {
    // Stop all motors
    digitalWrite(motor1Pin1, LOW);
    digitalWrite(motor1Pin2, LOW);
    digitalWrite(motor2Pin1, LOW);
    digitalWrite(motor2Pin2, LOW);
  }
}
Code tip: The NIC2262/2272 module outputs a simple HIGH or LOW on its data pin. For multi-directional control, use a 4-channel RF module — each channel output connects to a separate Arduino pin and maps to a movement direction (forward, back, left, right).
Adding Speed Control
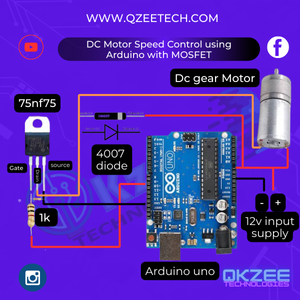
The sketch above runs the motors at full speed because the ENA/ENB jumpers are fitted. To control speed, remove both jumpers, connect ENA → D9 and ENB → D10 (both are PWM pins), and drive them with analogWrite():
int enaPin = 9;   // L298 ENA — PWM
int enbPin = 10;  // L298 ENB — PWM

void setup() {
  pinMode(enaPin, OUTPUT);
  pinMode(enbPin, OUTPUT);
  // ... the rest of the setup from the main sketch
  analogWrite(enaPin, 200);  // ~80% speed
  analogWrite(enbPin, 200);
}
Important: with the jumpers removed, the motors get NO power until ENA and ENB are driven — if you remove the jumpers and forget the analogWrite() lines, the car will not move at all.
Hardware & Software Explanation
Hardware
Arduino Uno is the brain of the robot. It reads sensor inputs and controls all outputs — in this case, the motor driver pins. Its 5V output also powers the RF receiver module directly.
L298 Motor Driver uses H-Bridge circuits to let the Arduino control the polarity (and optionally speed via PWM) of the DC motors. It handles the higher current demands of the motors so the Arduino doesn’t get damaged.
NIC2262 / NIC2272 RF Modules operate typically at 315 MHz or 433 MHz. The transmitter (NIC2262) in the handheld remote sends encoded signals; the receiver (NIC2272) on the robot decodes them and outputs HIGH/LOW on its data pins.
18650 Batteries are 3.7V rechargeable lithium-ion cells. Two in series give ~7.4V which is suitable for powering the L298 motor driver and the Arduino via VIN.
Software
Arduino IDE is the free development environment used to write, compile, and upload the sketch to the Arduino board. Download it from arduino.cc. No additional libraries are required for basic RF reading — digitalRead() is sufficient for the NIC2272 output.
Upgrade & Expansion Ideas
Once the basic car is working, here are some popular enhancements:
Replace the Arduino Uno with an ESP32 or ESP8266 to add Wi-Fi and Bluetooth control. Use Firebase, Blynk IoT, or ThingSpeak to build a full IoT-enabled robotic car controllable from a smartphone app. Add an HC-SR04 ultrasonic sensor (Rs 200) for autonomous obstacle avoidance — see our obstacle-avoidance robot car guide for the full wiring and code. Incorporate PWM speed control through the L298’s ENA/ENB pins for variable speed (see “Adding Speed Control” above). Use a 4-channel RF module for full directional control (forward, backward, left, right). This project also pairs well as a foundation for computer vision and image processing projects using a camera module.
Where to Buy the Parts
Hall Road Electronics Market in Lahore is the go-to destination for all the components listed in this guide — Arduino boards, L298 motor drivers, RF modules, 18650 batteries, chassis kits, and more. Most components are available at competitive student-friendly prices.
QKZee Technologies offers components, consultation, and full project execution for students and professionals. We specialize in robotics, IoT, automation, 3D printing, and engineering FYPs across Lahore and Pakistan. Every part in the components table above links to its product page on our shop, with the price shown — order online or visit us at Shop #20, 1st Floor, AL-KHALIL Center, Hall Road, Lahore. The NIC2262/NIC2272 RF module is not listed on the shop — message us on WhatsApp and we can arrange it on order.
Still Stuck?
If your car doesn’t move, the remote doesn’t respond, or the motors only spin one way, message us on WhatsApp and we’ll help you debug it — or watch the build on our YouTube channel.
Frequently Asked Questions
Q1: How do I make an RF-controlled robot with Arduino?
Connect the NIC2272 RF receiver’s data pin to Arduino D2. In your code, use digitalRead() to read the signal and control the L298 motor driver pins accordingly. The NIC2262 handheld remote sends HIGH when a button is pressed.
Q2: Can I use an ESP32 instead of Arduino Uno?
Yes. ESP32 and ESP8266 work well as upgrades and add Wi-Fi/Bluetooth capabilities, enabling IoT integration with apps like Blynk, Firebase, or ThingSpeak for smartphone control.
Q3: Is this project suitable for a final year project (FYP)?
Absolutely. This is a solid FYP base that can be expanded with additional features such as IoT connectivity, obstacle avoidance sensors, camera modules, or CNC/automation integration to meet university project requirements.
Q4: Where is the best place to buy electronics parts near Hall Road, Lahore?
Hall Road Electronics Market is the best-known hub for affordable components. QKZee Technologies also offers curated parts and project kits at student-friendly prices with expert consultation.
Q5: Can this project be upgraded to IoT?
Yes — swap the Arduino Uno for an ESP32, then integrate with Firebase, Blynk IoT, or ThingSpeak for cloud-based control and monitoring from any smartphone.
Conclusion
An RF remote robotic car is one of the best first robotics projects: the wiring is simple, the code is short, and the result — a car that drives from a handheld remote — is satisfying to demo. Start with the single-channel version in this guide, then add speed control and a 4-channel module when you want full steering. If you build it, send us a video — we’d love to see it.